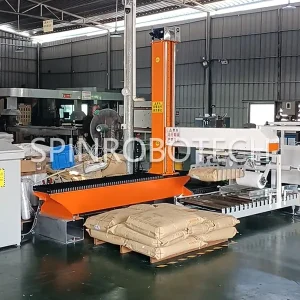
We have customized a Cartesian XYZ palletizer for one of our clients to enable efficient palletizing on their plastic pellet production line. معلومات التعبئة والتغليف والخط للمنتج الحالي هي كما يلي:
اسم المنتج: الكريات البلاستيكية
نموذج التعبئة والتغليف: أكياس PP
مواصفات المنتج: 20 كجم/كيس
أبعاد المنتج: 650×550×160 mm
أبعاد البليت: 1300×1100 ملم
نمط التراص: 4 أكياس لكل طبقة, 9–10 layers
إجمالي ارتفاع البليت: 1600 مم
وبناء على المعلومات الأساسية المذكورة أعلاه, we recommended and customized a Model 160 Cartesian XYZ palletizing robot for the client, equipped with a custom-designed gripper. معلمات الآلة هي كما يلي:
| حدود | |
| قوة | تيار متردد 380 فولت ±/5% ثلاثي الطور وأربع أسلاك |
| متطلبات الهوائية | Grippers: 0.6-0.8 MPa, ≥0.3 م3/دقيقة
إجمالي سعة خزان الهواء >600 ل |
| أبعاد | الارتفاع الكلي 2.6 م, الطول 2.5 م, العرض 2.1 م
Footprint 2.5×2.1 m² |
| طول الكابل | 3م (من جسم الروبوت إلى خزانة التحكم) |
| Palletizing Height | ≥1600 مم |
| النطاق القابل للتطبيق | 10-50منتج كجم
مشتمل: أكياس, كرتون, أوراق, كتل, أو منتجات مماثلة |
| كفاءة البليت | 300-400 دورات / ساعة (الحد الأقصى النظري) |
| استهلاك الطاقة | جسم الروبوت: 6.5 كيلوواط |
| مرجع البليت | ≥1200 × 1400 مم (بما في ذلك نمط المكدس الفعلي) |
| عنصر قابل للتخصيص | طول الذراع المتقاطع, ارتفاع العمود, طول القاعدة, القابضون الخاصة |
| متابعة الترقية | هوية الرؤية, خط ناقل البليت
Ton bag lifting reciprocating mechanism, نظام الربط المضاد للانهيار |
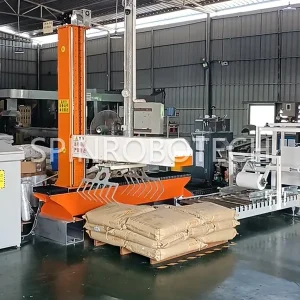
The machine has passed acceptance inspection and is currently in the process of applying for CE certification.
نحن نوفر ثلاثة روبوتات منصات نقالة رئيسية: روبوتات الإحداثيات الديكارتية, منصة نقالة من نوع العمود, والأسلحة الآلية المفصلية. للحصول على معلومات مفصلة حول أنواع آلات منصات التحميل الثلاثة, انقر هنا: حلول المنصات الآلي: دليل كامل للديكارتي, نوع العمود, والروبوتات المفصلية
Cartesian XYZ Palletizer: الاختيار المستقر للدقة والأحمال الثقيلة
تصميم احترافي:
Based on the Cartesian coordinate system, adopting a gantry or column-type framework. The core consists of three sets of linear motion units: X-axis (horizontal left/right), Y-axis (horizontal forward/backward), and Z-axis (vertical up/down). To balance the torque caused by long-travel cantilevers, the Y and Z axes often employ dual linear units and dual sliders to ensure motion stability and mechanical rigidity. An optional A-axis (rotation) can be added to handle complex materials, forming a 4-axis configuration.
مسار الحركة:
The end effector moves only linearly along the X, ي, and Z axes. The trajectory type is simple, completing point-to-point transfers through combinations of three-directional linear displacements. Its working envelope is a precise rectangular or cuboid space.
السيناريوهات المطبقة والمشتركة:
Leveraging high rigidity and heavy load capacity, it is especially suitable for handling heavy, large, and regularly shaped materials. Widely used in industries such as automotive manufacturing, مواد البناء, metallurgy, and heavy machinery. Common scenarios include the handling and palletizing of molds, metal ingots, plates/panels, heavy parts, and other regular-shaped objects.
SPIN – منصات نقالة احترافية & مزود حلول الروبوتات لإزالة المنصات
نحن نقدم خدمة الشباك الواحد بدءًا من الاختيار والتخطيط وحتى دعم ما بعد البيع. اتصل بي للحصول على حل مخصص يعتمد على المواد والموقع الخاص بك!